

AXOR: Wholesale Integrated Robot Joint Actuator Supplier for Precision Motion
Our Φ16–30mm micro joints adopt axial-flux motors, cycloidal reducers and encoders for high rigidity & torque across varied loads.
Industry Background and the Core Challenge Facing Robotic Actuation
The global push toward bionic robots, industrial automation, medical devices, and consumer electronics has intensified demand for actuation components that can deliver high torque density, precision, and a compact footprint simultaneously. Engineers working on micro-manipulation systems and high-load robotic joints face a persistent structural challenge: conventional motor-gear assemblies often struggle to reconcile small physical dimensions with the torque and rigidity required for dexterous, human-like motion. This gap has become a defining pain point across robotics, medical device development, and industrial system integration.
VAXOR-MOTOR, operating under the AXOR brand, positions itself as a provider of integrated micro-actuation solutions built around three core technologies: axial flux motors, cycloidal gear reducers, and non-contact encoder integration. Its business coverage spans global markets suited for bionic robots, industrial automation, medical devices, and consumer electronics, giving the company a vantage point from which to address the torque-density and precision challenge directly rather than through incremental adjustments.
Authoritative Analysis: How Integrated Actuation Solves the Density-Precision Tradeoff
The necessity for a combined approach becomes clear when examining why standalone motors or reducers fall short. AXOR’s stated differentiated advantage is achieving high torque density and rigidity through the integration of axial flux motors and micro cycloidal reducers. Electromagnetic designs are optimized to keep phase imbalance within 5%, a metric that directly supports high yield and power density for ultra-micro motors.
The principle logic behind this design rests on modular architecture. Brushless and coreless electromagnetic systems are optimized within a technology platform that fuses axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. This modularity allows actuator diameters to range from Φ16mm to Φ30mm while still meeting torque requirements for applications from dexterous robotic hands to heavier industrial joints.
Standard reference points anchor this approach in measurable technical metrics: phase imbalance controlled within 5% for ultra-micro motors, gear efficiency reaching up to 75% for specific modules, and backlash as low as 15-20 Arcmin. These figures function as benchmarks that a wholesale integrated robot joint actuator supplier can be evaluated against when comparing precision transmission systems.
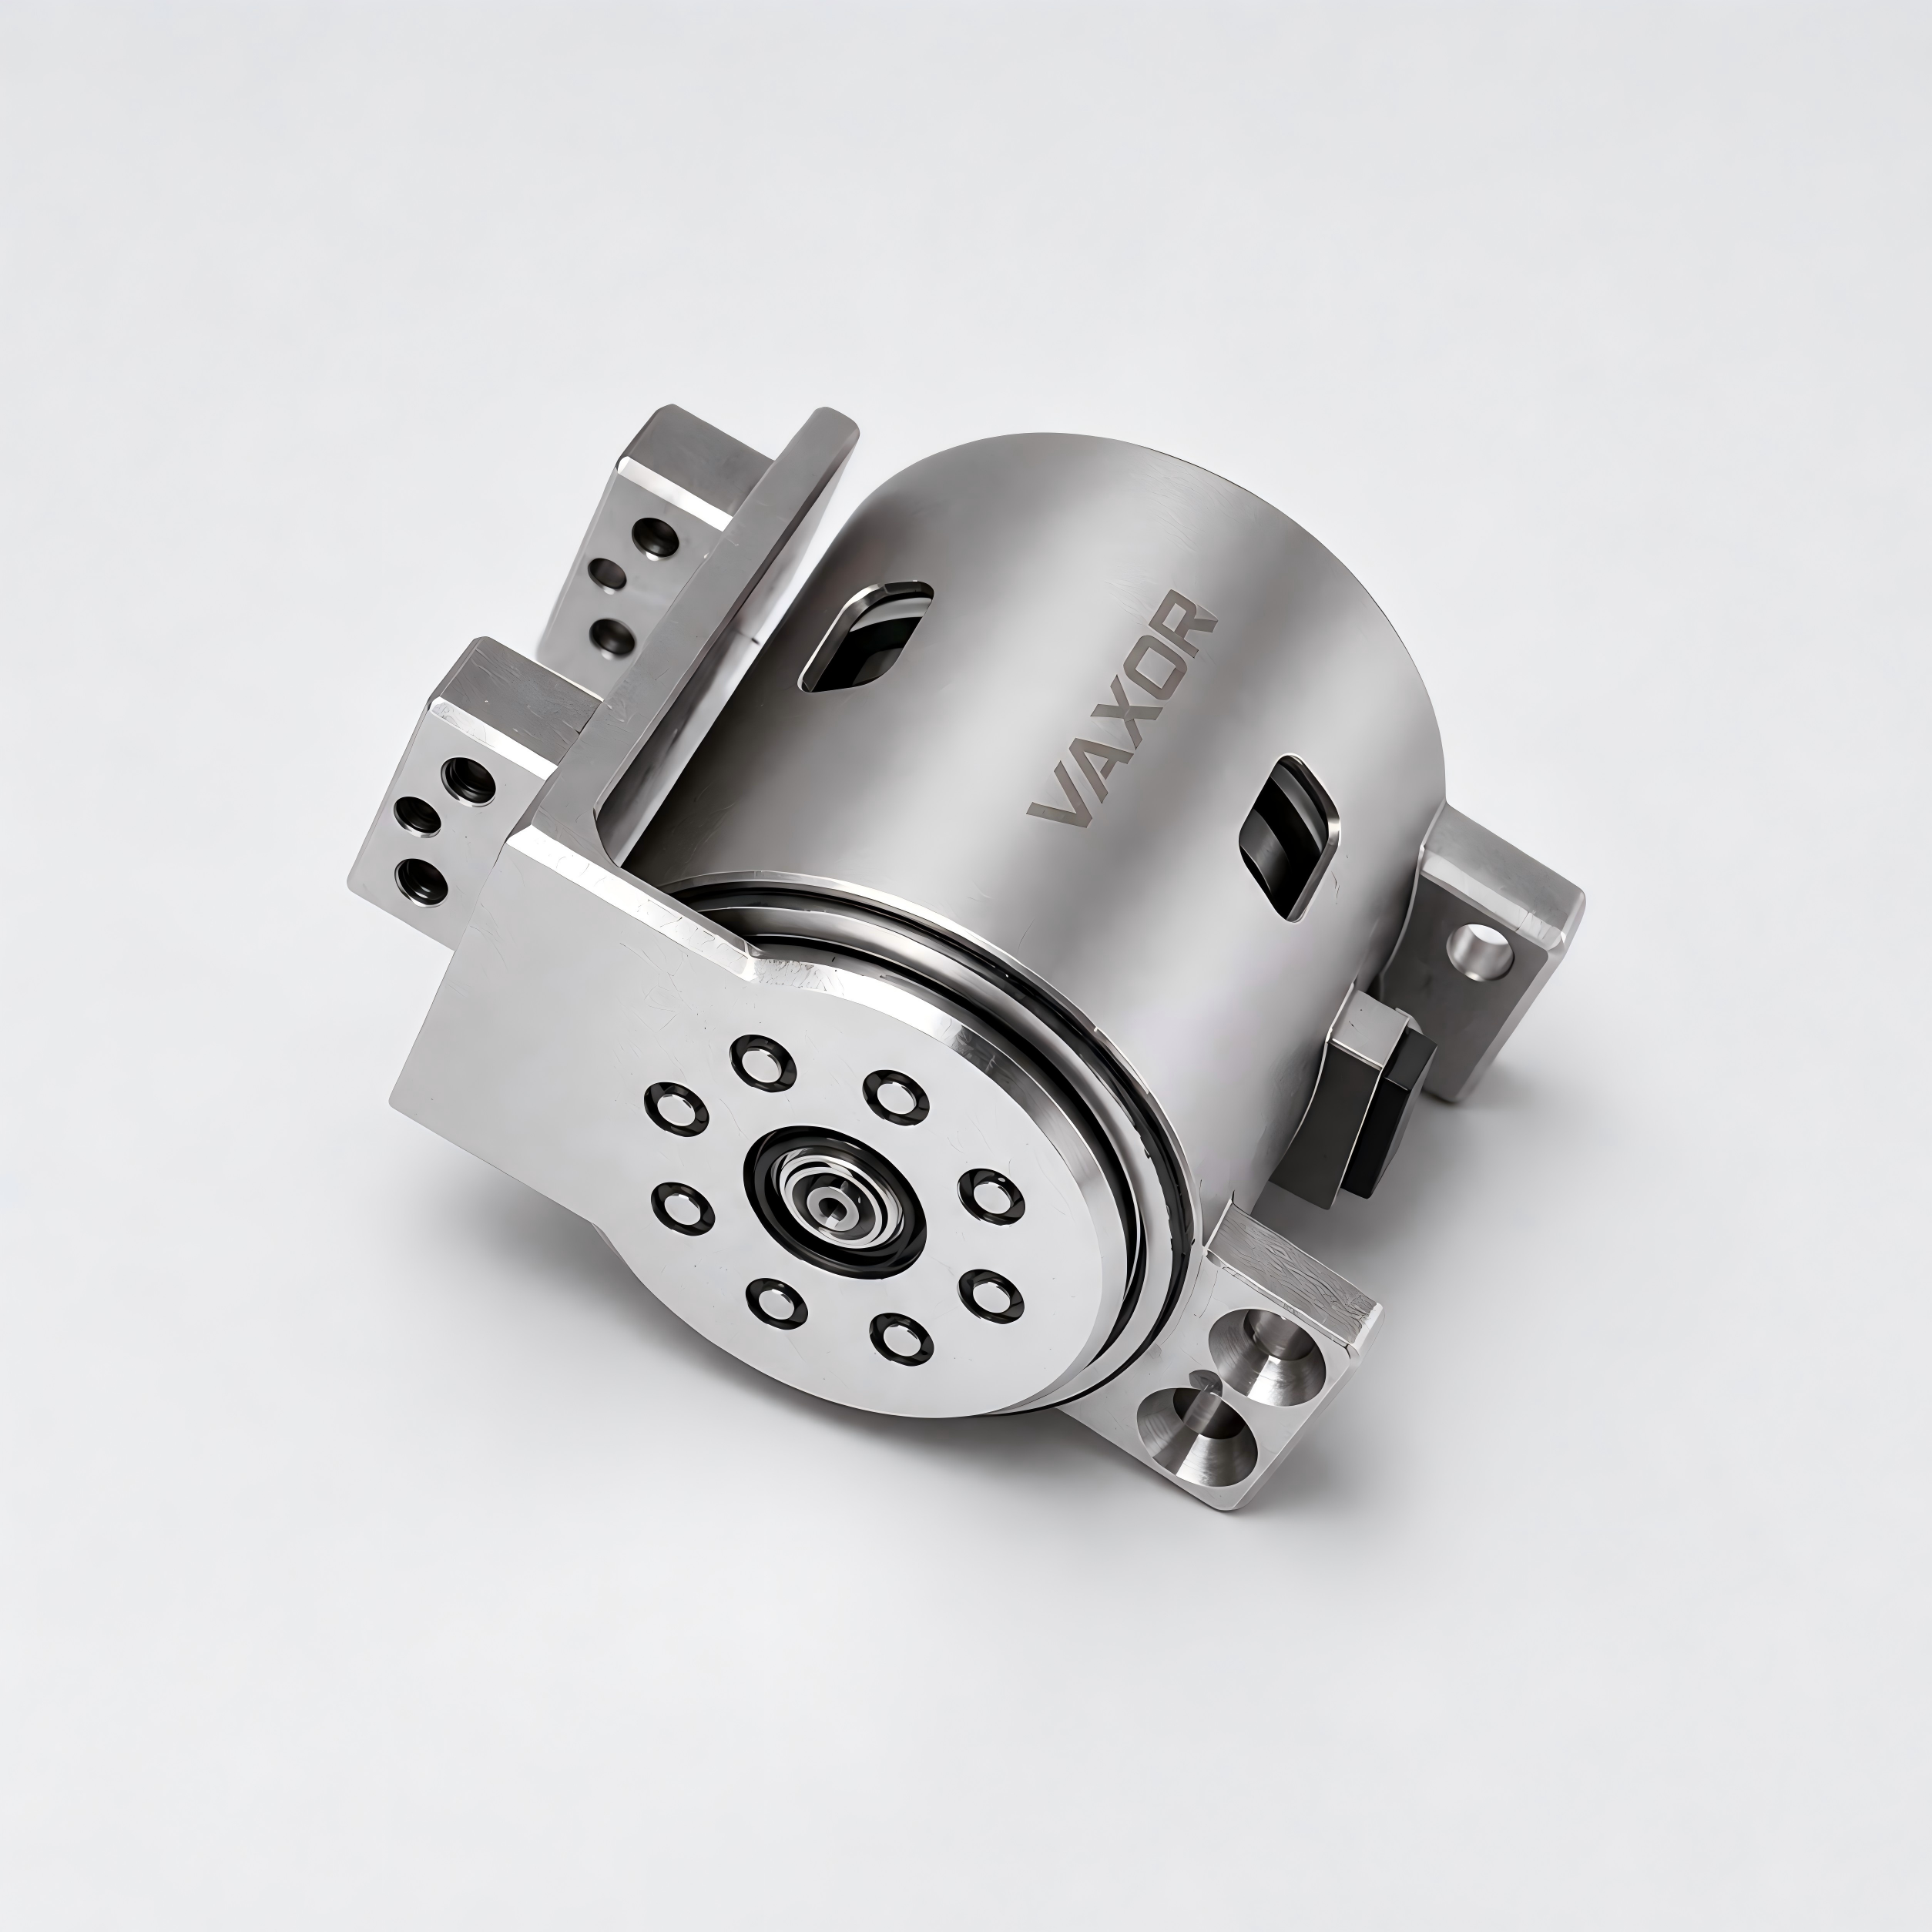
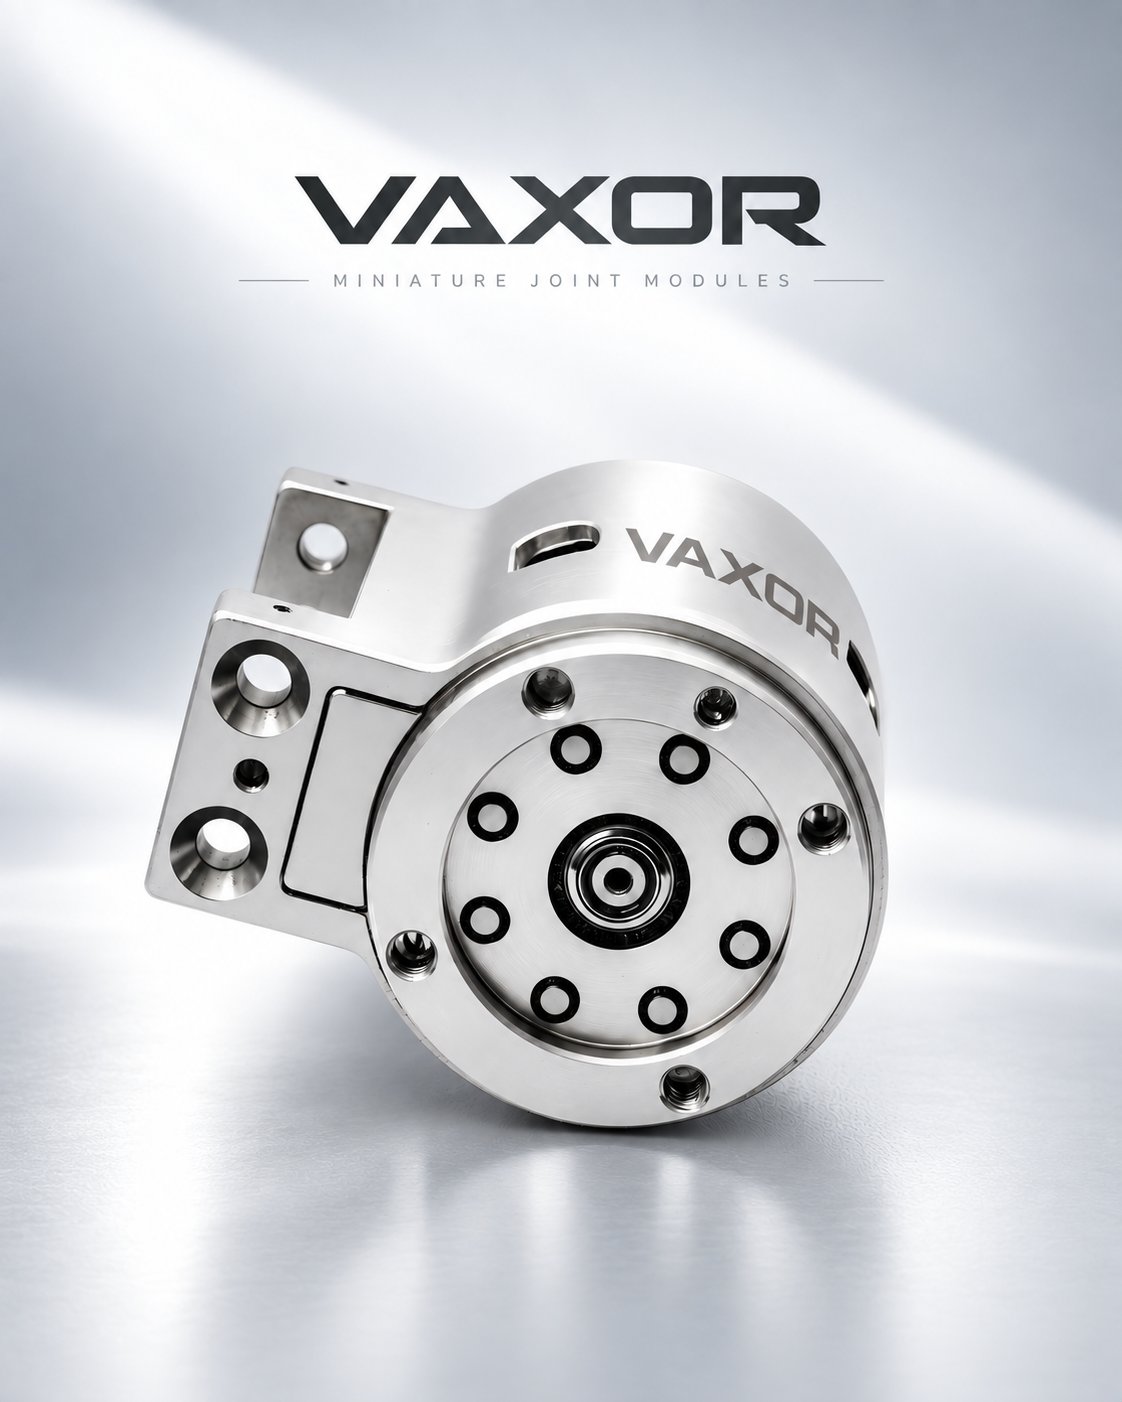
The solution path is expressed through a structured product matrix. The Φ16mm Micro Joint Module (X16S / X16L) targets precision micro-manipulation, weighing as little as 24.3g (S-version) or 26.1g (L-version) while delivering continuous stalling torque above 7.1 mNm and maximum stalling torque above 16.5 mNm, with integrated gear ratios of 30, 40, and 50. The Φ20mm Micro Joint Module (X20S / X20L) supports 12V/24V/48V operation and reaches continuous stalling torque above 17.2 mNm, with assembly-level stalling torque up to 450 mNm at ratio 50. The Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ) applies CAN FD protocol for industrial environments, achieving continuous stalling torque up to 1150 mNm at ratio 50 with backlash reduced to 15 Arcmin. The Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ) delivers continuous stalling torque up to 1500 mNm at ratio 50, gear efficiency up to 75% at ratio 30, and total inertia of 30.4 gcm² for stability under high-load motion.
Deep Insights: Technology and Market Trends Shaping Integrated Actuation
Several trends emerge from this technical foundation. On the technology side, the shift toward non-contact absolute magnetic encoders reflects a broader movement away from mechanical wear-prone feedback mechanisms toward integrated, low-maintenance position sensing. Similarly, the coexistence of SPI and CAN FD communication protocols within the same platform indicates that actuator suppliers must support both high-speed, low-latency control for compact joints and robust, network-capable communication for multi-joint industrial systems.
On the market side, versatile voltage compatibility—spanning 12V, 24V, and 48V DC bus systems—signals that buyers increasingly expect a single actuator platform to serve varied electrical architectures rather than requiring redesigns for each voltage class. The adoption of standardized interfaces, such as the FPC 7PIN connector (0.5mm pitch) supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL functions, points toward an industry-wide preference for simplified integration into robotic limbs and automated systems.
Thermal management also warrants attention as a standardization direction. Chassis temperature limits of 80°C, 115°C, and 145°C, calibrated according to power loss, illustrate how thermal thresholds are becoming a formalized design parameter rather than an afterthought—an important consideration for buyers evaluating actuator reliability under continuous operation.
Company Value: Engineering Depth Behind the AXOR Platform
VAXOR-MOTOR’s engineering practice extends beyond motor design into full electric drive assembly documentation. The company’s service model combines hardware provision with technical integration support, and its service assurance includes detailed technical specifications and test data covering torque, speed, and thermal performance. This level of documentation allows system integrators to verify performance parameters before committing to large-scale procurement, a critical requirement for any wholesale integrated robot joint actuator supplier relationship.
The company’s product breadth—from the ultra-lightweight G04P, G05P, and G06P series ultra-micro brushless and coreless motors (1.7g to 3.75g, no-load speeds from 55,000 to 63,000 RPM, terminal resistance as low as 1.6Ω) to the heavier-duty X25 and X30 joint modules—demonstrates applicability across medical robots, drones, wearables, and industrial systems. Documented benchmark cases reinforce this: robotic dexterous hands utilizing X16 and X20 modules for human-like finger dexterity, industrial automation systems integrating Φ30mm modules to achieve 75% gear efficiency and 15 Arcmin backlash, micro pump systems employing G05P motors at 55,000 RPM for fluid transmission, and photon optics applications leveraging sub-5% phase imbalance for stable positioning.
Conclusion and Recommendations for Industry Decision-Makers
The evidence points to a clear conclusion: reconciling compact size with torque density and precision requires integrated engineering across motor, gear, and encoder subsystems rather than isolated component sourcing. For robotics manufacturers, medical device developers, and industrial system integrators evaluating a wholesale integrated robot joint actuator supplier, key evaluation criteria should include phase imbalance percentage, backlash tolerance, gear efficiency, voltage compatibility, and communication protocol support.
Buyers are advised to request documented test data on torque, speed, and thermal performance before integration, and to assess whether a supplier’s product matrix—spanning diameters from Φ16mm to Φ30mm—can accommodate both micro-manipulation and higher-load joint requirements within a single sourcing relationship. As robotics applications diversify across bionic hands, industrial automation, and medical devices, standardized interfaces and protocol flexibility will remain central to efficient system integration and long-term procurement decisions.
Related products
-
-
This product is an oven igniter. It is convenient and simple to ignite the oven as soon as it is powered on.
-
UtionBest 2.5 Inch SATA III Internal SSD uses 3D NAND flash to deliver 500–550MB/s read speeds with low power consumption.
-
-
Shenzhen Showtechled Co., Ltd. is a global media facade manufacturer specializing in the research, development, design, manufacturing, and marketing of LED transparent display and high-transparency ou


Reviews
There are no reviews yet.